Research Intern
BAAI · Embodied vision-language-action model pretraining
Thanks for stopping by!
I am a Ph.D. student at the Institute of Automation, Chinese Academy of Sciences. My research interests include prompt learning, domain generalization, and representation learning for vision-language-action models.
My current projects explore generalizable action representations for embodied intelligence, including covariant action modeling, semantic-action manifold alignment, and human-to-robot transfer for robotic manipulation. Learn more about my research interests in publications.
Get in touch by sending me a note.
Belief. Intelligence emerges when generalizable multimodal representations become stable.
My current work centers on VLA training and representation learning for embodied intelligence. I am interested in how vision-language-action models acquire compact, transferable action spaces that support robust manipulation and generalization.
I am a Ph.D. student at the Institute of Automation, Chinese Academy of Sciences, supervised by Changsheng Xu. I am broadly open to research collaborations, visiting opportunities, and industry research roles around embodied AI, robot learning, and multimodal foundation models.
BAAI · Embodied vision-language-action model pretraining
CASIA · Pattern Recognition and Artificial Intelligence
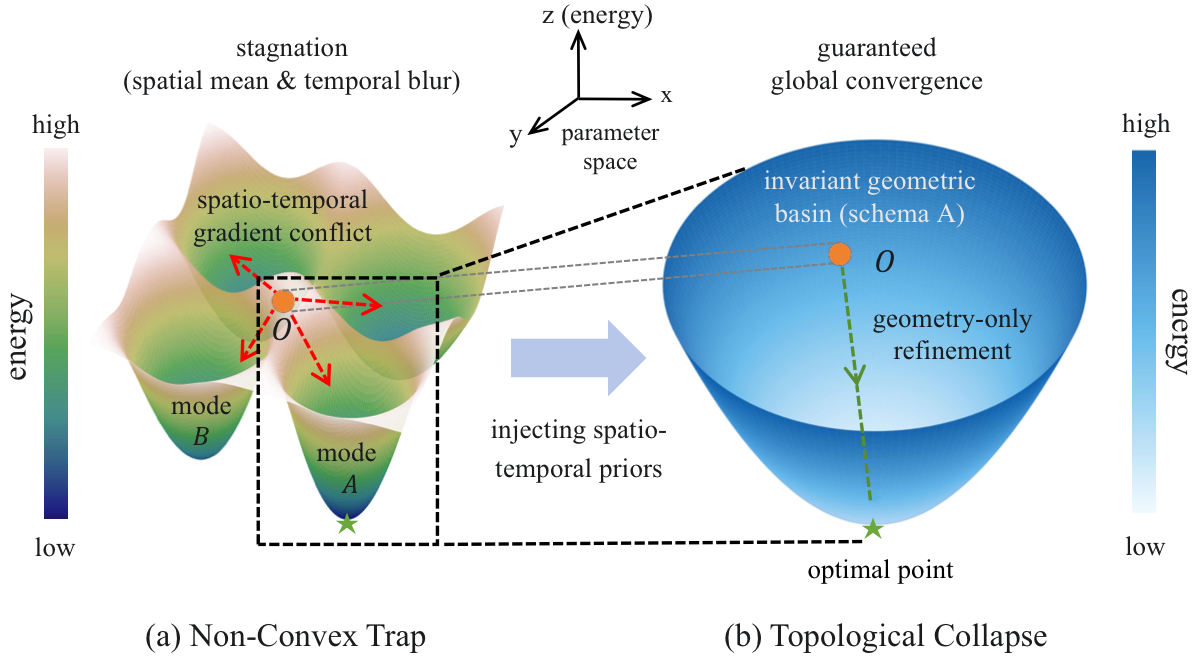
Constructing generalized manifolds for action learning through spatio-temporal decoupling.
See project ->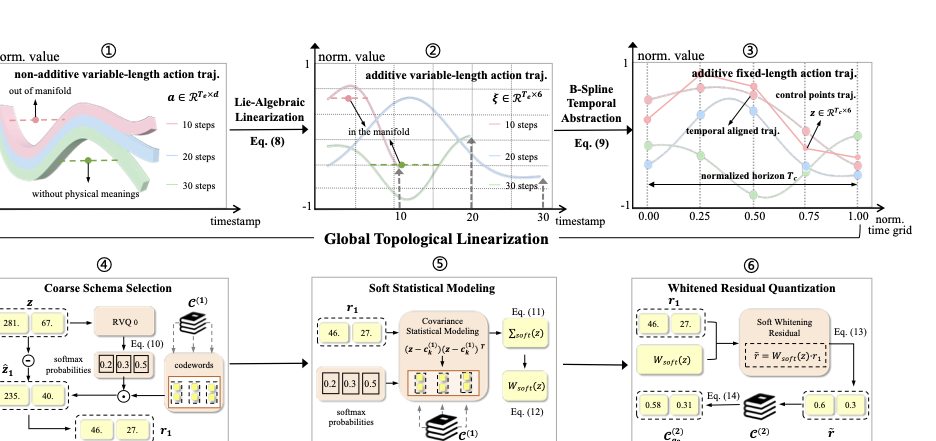
Bridging vision-language and action manifolds via Gromov-Wasserstein alignment.
See project ->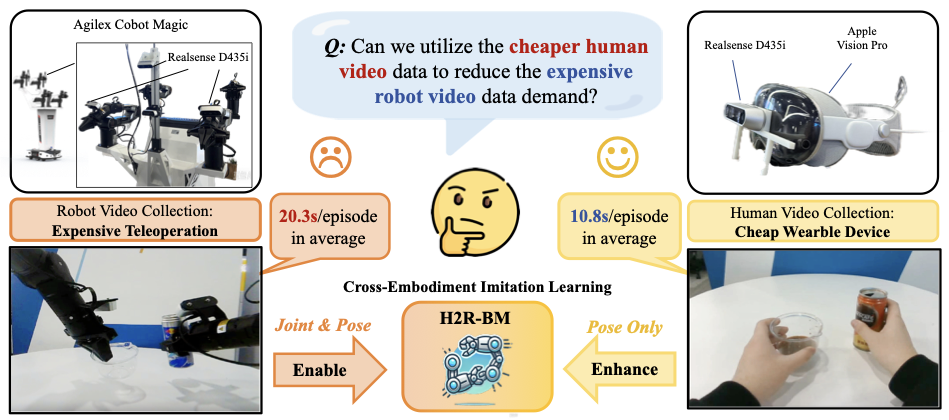
Leveraging human videos to improve generalization in robotic bimanual manipulation.
See project ->